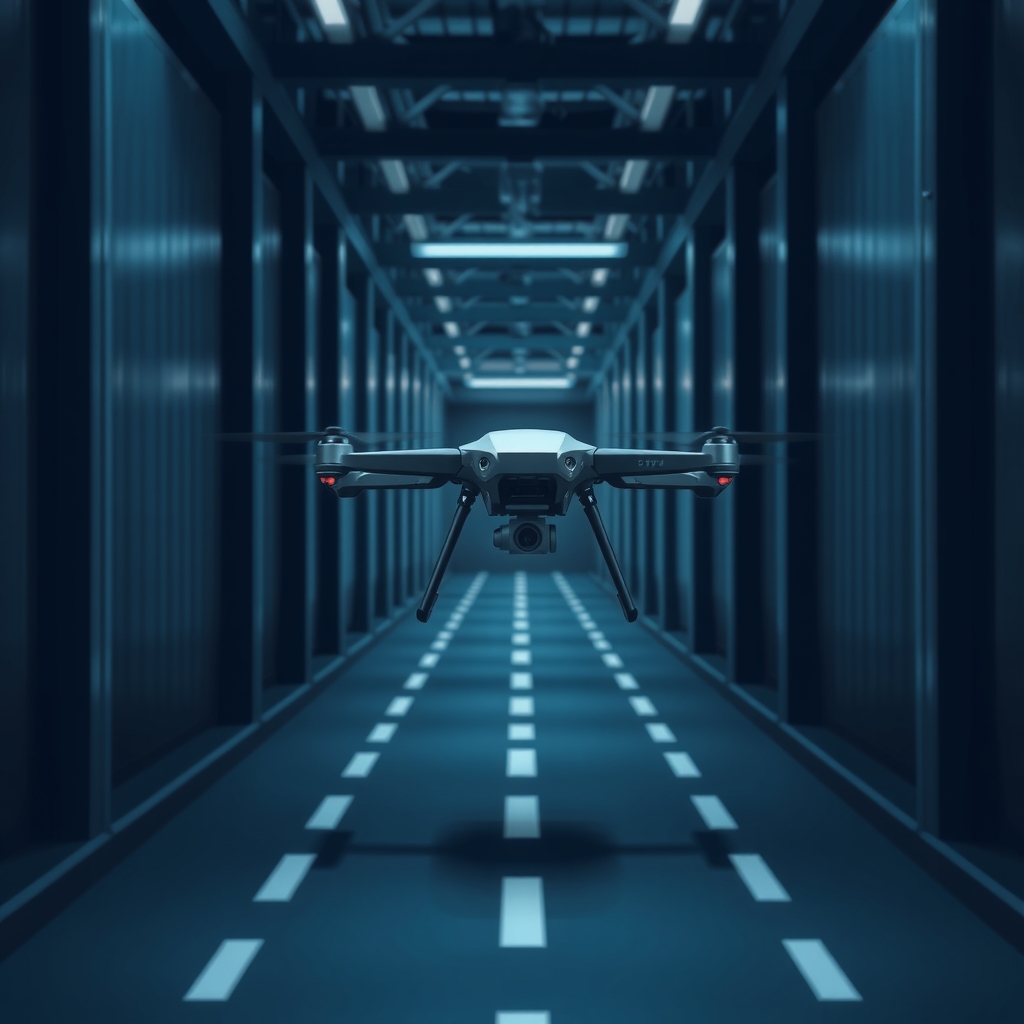
MIT researchers have presented SANDO, a trajectory-planning system for uncrewed aerial vehicles. According to the institute, the method builds a route through an unmapped environment and provides a mathematical guarantee that the vehicle will avoid collisions, even when unknown obstacles move unpredictably. The planner only needs information about the maximum speed an obstacle could reach. MIT identifies search and rescue, mine exploration, and delivery in crowded neighborhoods as potential applications. The work is described in a paper published in IEEE Transactions on Robotics.
RoboticsBriefs
MIT presents a flight planner designed to avoid collisions
MIT's SANDO system is designed to guarantee a safe drone path, including in unmapped environments where obstacles can move.
Content produced with the assistance of artificial intelligence by TAMUSNI.